01
Identify the suite
Keep suite identity, scope and declared versions aligned before comparing records.
A Python SDK and CLI for replaying recorded fixtures and comparing versioned results within a declared suite and scope.
Explore the workflow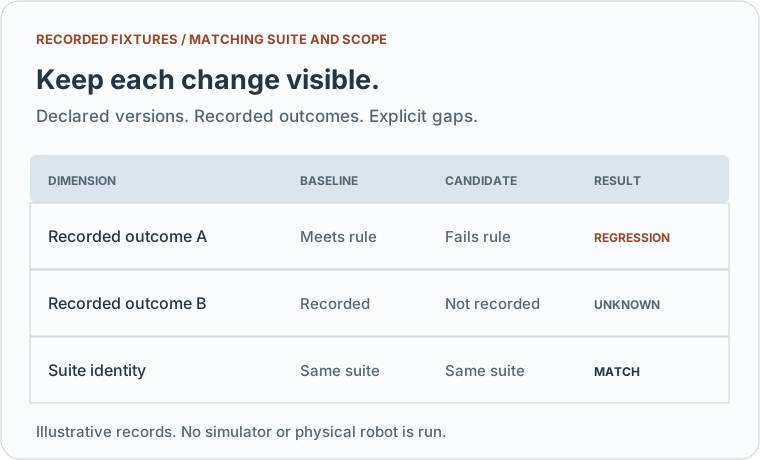
You need to compare baseline and candidate records under the same declared suite and scope.
Keep suite identity, scope and declared versions aligned before comparing records.
Read 12 manually recorded observations with fixed seed identities. The seeds do not run or randomize a simulation.
Keep Unknown dimensions explicit. A known regression takes precedence over an improvement elsewhere.
The Python 3.10+ standard-library example returns predetermined fixture records. Contract-invalid input is rejected. A valid comparison is a record-level result, not a physical-system test.
Baseline and candidate: same suite identity and scope.
Dimension A: candidate regresses against the baseline.
Dimension B: candidate improves.
Overall comparison retains the regression; missing evidence stays Unknown.
The package runs no simulator, physical system, trained policy, sensor or safety controller. It establishes no physics fidelity, robot safety or real-policy performance. Fixture metadata and digests bind records but do not authenticate their origin. CLI success means a valid comparison, not acceptance or safety.
Describe the input, the outcome you need to verify and who can accept the result. Start with nonconfidential information. Leave out customer records, personal information and credentials.
Contact RoboCairnhello@robocairn.com · Opens your email app.